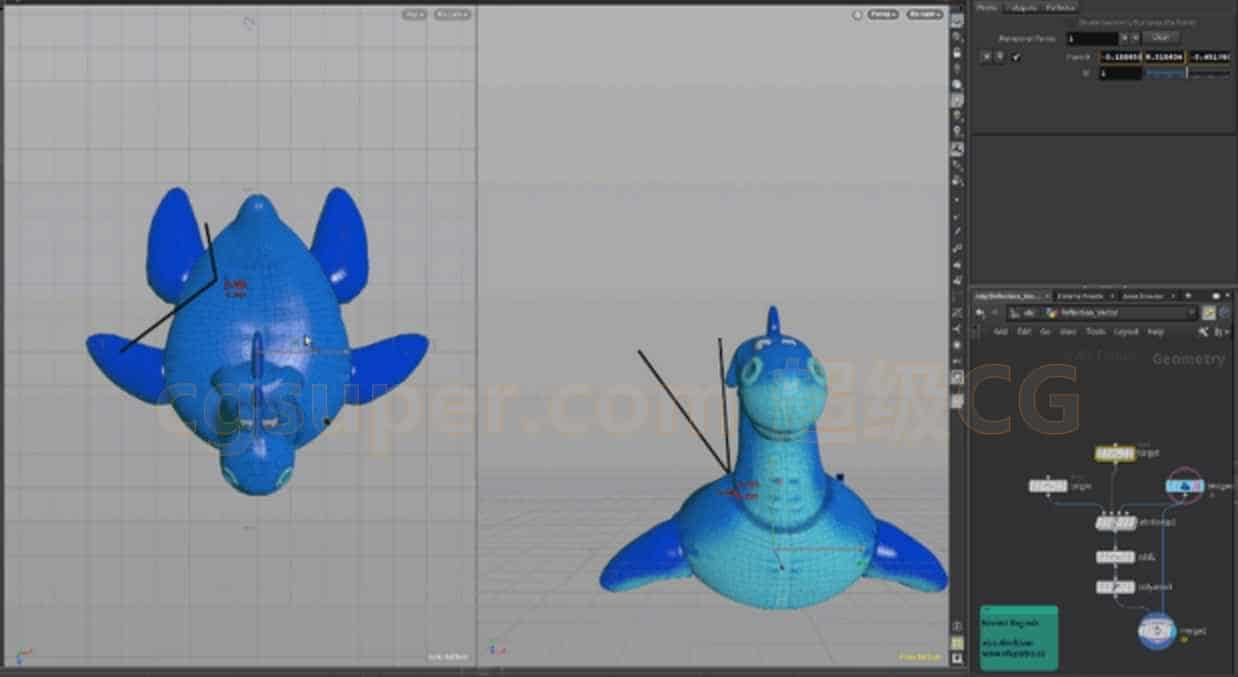
As simple as the title suggests, you will need an origin point and a target one to drive the direction and the collision model, I developed this tool while working on flocking collision avoidance behavior where the velocity vector will act as the reflection direction.
正如标题所暗示的那样简单,你需要一个原点和一个目标来驱动方向和碰撞模型,我在研究植绒碰撞避免行为时开发了这个工具,其中速度矢量将作为反射方向。

THE END